Compression Mold
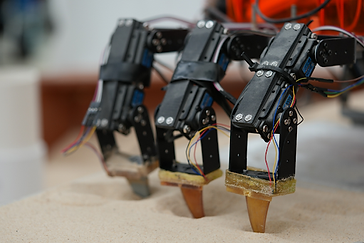
A part of a larger digging crab robot project, this compression mold was designed to mold a crab dactyl inspired end effector from a novel polymer with tunable mechanical properties.
Theory
Since compliant end effectors inherently introduce error in the position control of robotic joints, the implementation of a magnet which will move with the deformation of the end effector allows for a magnetometer to estimate the state of the dactyl. By using a novel polymer developed by the Root Lab, the exact elasticity can be varied across the dactyl, allowing for additional control in tuning mechanical properties.

Design
This compression mold was designed to be used in conjunction with a heat press. By taking advantage of the thermal conductivity of aluminum, the polymer used could be taken to its working temperature while remaining as pellets to be compressed into shape.

Manufacturing
I personally created CAM for all parts of this mold operated the CNC mill to produce geometrically complex profiles from solid bodies.

